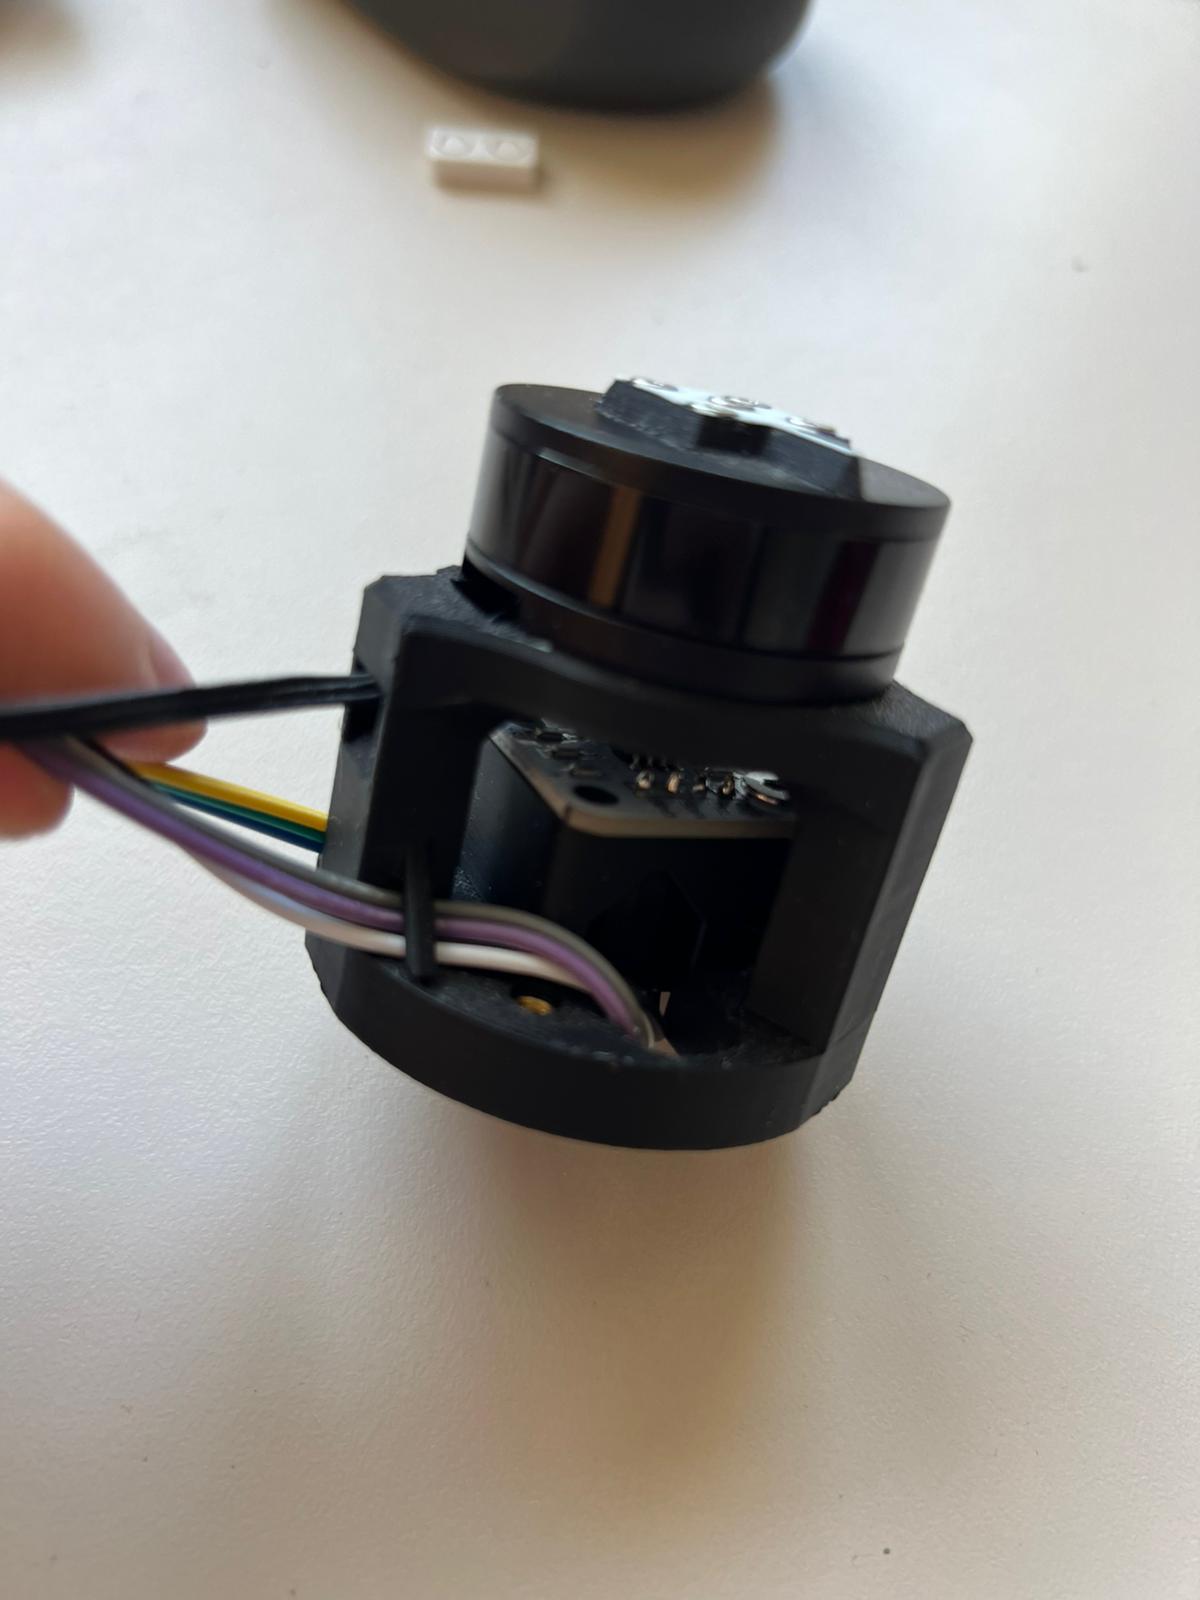
My goal is to create a gimbal to hold a sensor array that is looking at/tracking an object. Pan up/down, spin left/right. I am new to FOC, but not electrical engineering. My MCU will be the ESP32-S3, the sensor array will be ~120g (with one of the gimbal motors inside it).
I am going for smooth, slow motion.
I do not need it to be very strong/high torque (I think).
I have been looking at 2804 sized gimbal motors. Also some 2208 ones. I intend to do a closed loop setup (two INA240 current sensors per gimbal) with encoders.
Things I am confused on that I hope someone can point me in the right direction:
- Encoders, they seem to vary in price a lot.
- Drivers, the SparkFun board I got uses the TMC6300 vs the TI DRV8313, I am going for a lower power system (2S Lipo battery ~7.4v), any concerns with the TMC?
- AS5600 vs AS5048a, again a price difference, some accuracy (12bit vs 14bit) I am not sure that is super important in my application. (and one is I2c and one is SPI)
- Also the SparkFun board uses TMAG5273 Hall effect sensor, but I have seen negative thoughts on this for a gimbal, not sure why tho.
- I2C vs SPI vs PWM - Most off the shelf gimbal motors + encoders seem to use the above two chips but in PWM mode. In practice is this fine? crappy?
- Heat - Ideally I want this to be slow and smooth, the sensor array will be balanced, I am thinking just low current should be fine here, if something pushes back I just want it to give up.
- ESP32-S3, does it generally work well if it is multitasking a bit? I can make dedicated thread for it.
- Is it worth using an off the shelf gimbal + encoder or should I just make my own encoder board setup? I am assuming most do not have the magnet needed so I will need to add that in the shaft.
- Lastly any advice on gimbal size / kV / turns? I have seen some small low kV, various turns, I feel this is all a balance I am not yet understanding.
Appreciate any guidance or pointing me in the right direction to find it!!
Ryan
 You’ll have to compromise with having “as low as possible” and getting “more RPM that needed”. So they don’t make them any better than 200kV. Sounds plausible.
So looking again, you said that you need a smooth operation and from what you said the ESP32-S3 with AS5600 will work fine. PWM can work fine too but I recommend using I2C The smoothness will depend on the control's project too so you'll need to take in mind more about the particularities design's PID and this kind of stuff (like how you'll organize your tasks in the threads for example)
– nanaEuahSadly I can't add any comment about the Kv
– nanaEuah